OEM/ODM Robotic Actuator Manufacturer & Factories

High-Torque Density Modular Actuators, Precision Servo Drive Assemblies, and Custom Mechatronic Solutions Engineered for Next-Generation Robotics & Industrial Automation.

ISO 13485 & ISO 9001 Certified 40+ Years Engineering Excellence Custom Winding & Gearing Options
Precision Product Portfolio

High-Performance Actuators & Servo Motor Assemblies

Explore our industrial-grade OEM/ODM robotic actuators, micro digital servos, AC servo kits, and position-feedback motors. Engineered for high torque ripple suppression, extreme duty cycles, and seamless bus communication.

AC Servo Motor 1300W 220V Support Pulse RS485

AC Servo Motor 1300W 220V Support Pulse / RS485 Control

High-precision 1300W AC servo built specifically for surgical robotic arms and medical laboratory automation requiring ultra-low EMI and RS485/Pulse protocol versatility.

Power / Voltage:1300W / 220VAC
Control Interface:Pulse / RS485 Modbus
Application:Medical & Industrial OEM
Get a Quote
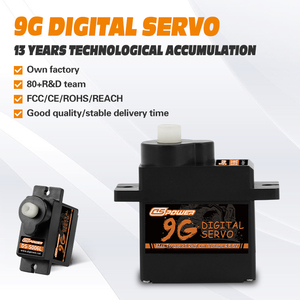
SG90 Servo Motor PWM Plastic Gear Micro Servo

SG90 / MG90S Micro Servo Motor PWM 180° Precision Gear

Ultra-compact 9g micro servo motor designed for lightweight robotic end-effectors, micro-actuation, and high-frequency PWM positioning modules.

Weight / Gear:9g / Metal or Plastic
Rotation Angle:180° PWM Control
Target Use:Gripper / Micro Actuator
Get a Quote
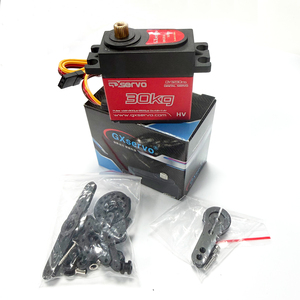
GXservo 30KG Torque Digital Servo Motor Waterproof Metal Gear

GXservo 30KG Heavy-Duty Waterproof Digital Metal Servo

IP67 waterproof digital actuator delivering 30kg.cm holding torque. Features hardened stainless gear trains for rugged legged robots and outdoor UAV mechanisms.

Torque Rating:30 kg-cm @ 7.4V
Ingress Protection:IP67 Sealed
Gear Train:Full Metal Titanium Alloy
Get a Quote
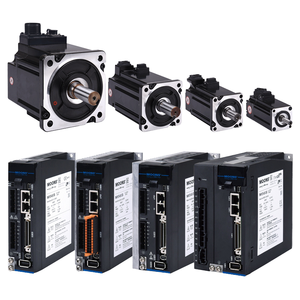
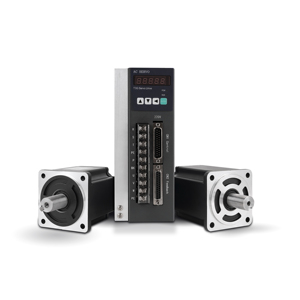
Servo Motor With Drive XP 750w 220VAC 2.4Nm Controller

XP 750W 220VAC Servo Motor & Driver Kit with 3m Cable

Integrated 0.75kW AC servo package with low-inertia rotor design, delivering 2.4N.m continuous torque for high-speed robotic picking and CNC gantry automation.

Output Power:750W (0.75kW)
Rated Torque:2.4 N.m Nominal
Kit Includes:Motor, Driver, 3m Harness
Get a Quote
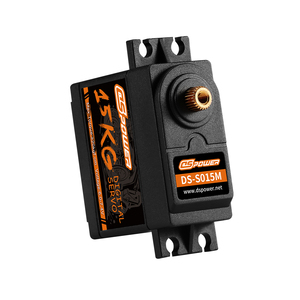
High-Speed RC Robot Motor Position Feedback 15kg Torque

High-Speed Modular Actuator with Closed-Loop Position Feedback

15kg.cm torque capacity smart servo with magnetic encoder feedback, enabling precise velocity profiling and position sensing in dynamic robotic joint systems.

Torque Rating:15 kg-cm
Feedback Type:12-Bit Magnetic Encoder
Speed:High-Velocity Response
Get a Quote
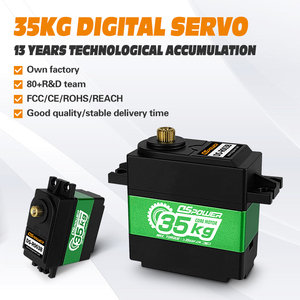
35KG Micro Servo Motor High Torque Universal Digital Servo

35KG Universal High-Torque Digital Metal Servo Actuator

Industrial-grade 35KG digital actuator with reinforced aluminum center housing for maximum heat dissipation during continuous heavy-duty robotic arm operational cycles.

Max Torque:35 kg-cm
Case Structure:CNC Machined Heat-Sink
Control:Digital High-Resolution
Get a Quote
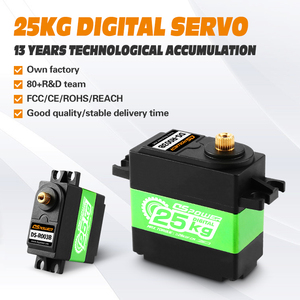
25kg Metal Gear Semi-aluminum case Servo Robotic Arm PWM

25KG Semi-Aluminum Robotic Arm PWM Servo Motor

Precision 25kg PWM servo utilizing hybrid steel gearing and dual ball-bearing output shafts to eliminate axial play in multi-articulated robotic joint mechanisms.

Torque Rating:25 kg-cm
Housing:Semi-Aluminum Alloy
Bearing System:Dual Heavy Ball Bearings
Get a Quote
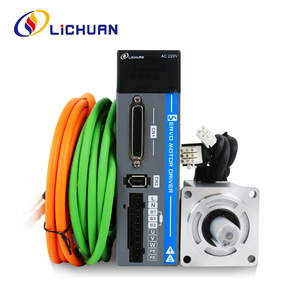
Lichuan 220V 3000RPM IP65 AC Servo Motor Driver A5 Series

A5 Series 220V 3000RPM IP65 AC Servo Motor & Driver System

Industrial IP65 AC servo kit scaling from 200W up to 1000W output. Tailored for harsh industrial environments, AGV drive wheels, and automated assembly machinery.

Power Range:200W - 1000W Scalable
Rated Speed:3000 RPM Nominal
Protection:IP65 Waterproof / Dustproof
Get a Quote
Proven Manufacturing Metrics

OEM/ODM Engineering Capabilities at a Glance

1985
Engineering Legacy Established in Houston, TX
< 1 arcmin
Ultra-Low Backlash Strain Wave Options
4-6 Wks
Rapid Turnaround for Modified Prototypes
100%
Full FEA Thermal & Magnetic Traceability
Enterprise Value Proposition

Why Leading Robotics Original Equipment Manufacturers Partner with Us

Designing modern robotic systems requires more than off-the-shelf motor catalogs. As a vertically integrated OEM/ODM manufacturer, we bridge the gap between electromagnetic physics, high-precision planetary/harmonic gearing, and smart drive firmware.

Custom Electromagnetic Winding & Magnetics

We optimize copper fill factors, slot-pole ratios, and rare-earth Neodymium (NdFeB) magnet configurations to achieve maximum torque density while minimizing cogging torque and thermal dissipation under continuous duty.

Zero-Backlash Gearing Integration

Our engineering team specializes in pairing brushless frames with strain wave (harmonic) reducers and high-precision planetary gearboxes, achieving positional accuracy down to sub-arcminute tolerances for robotic joints.

Medical & Industrial Regulatory Compliance

Backed by strict design controls, our manufacturing facilities produce subassemblies aligned with IEC 60601-1 medical electrical safety, ISO 13485 quality standards, low EMI profiles, and full lot traceability.

Smart Fieldbus Controller Embedded Units

Eliminate external drive cabinets. We integrate compact Field-Oriented Control (FOC) drivers directly inside actuator end-caps, natively supporting CANopen, EtherCAT, Modbus RS485, and dual-encoder feedback protocols.

Dual-Source Supply Chain Resilience

Headquartered in Houston, Texas with audited partner foundries in Asia and North America, Telco provides localized buffer stock management, risk mitigation, and flexible production scheduling for global OEMs.

Integrated Battery & Power Subassemblies

We deliver total motion-and-power solutions, matching low-voltage BLDC robotic actuators with custom sodium-ion or lithium battery pack architectures, single-part-number ordering, and pre-validated system integration.

Market Intelligence & Sourcing Insights

Future Procurement Trends in OEM Robotic Actuators (2025–2030)

As autonomous mobile robots (AMRs), humanoid platforms, and collaborative surgical arms enter mass production, procurement strategies are undergoing a fundamental shift from component-level purchasing to integrated mechatronic module sourcing.

1. Transition from Discrete Components to All-in-One Frameless Actuator Modules

Traditionally, robotics OEMs sourced motors, planetary gearheads, optical encoders, and servo drives from separate suppliers. This fragmented approach introduced cumulative mechanical tolerances, complex wire harness routing, and elevated assembly labor costs. Future-proof procurement teams are prioritizing all-in-one smart actuators—compact rotary joints that integrate frameless BLDC stators, hollow-shaft harmonic drives, absolute encoders, and thermal sensors in a single sealed chassis.

By shifting to integrated actuators, engineering teams reduce bill-of-materials (BOM) complexity by up to 40% while accelerating time-to-market. Factory-certified calibration ensures uniform torque-to-weight ratios across every robotic joint module, establishing predictable thermal performance and simplified inventory management.

2. Demand for High Power Density & Low Cogging Torque Motors

In collaborative robotics (cobots) and medical device applications, force feedback sensitivity is paramount. Standard off-the-shelf industrial motors exhibit pronounced cogging torque—magnetic friction caused by rotor magnets interacting with stator slots—which distorts haptic control algorithms during fine delicate operations.

OEM buyers are actively seeking manufacturer partners capable of executing custom slot-pole combinations (such as 12-slot/14-pole or 24-slot/28-pole electromagnetic designs) alongside skewed stator laminations. These specialized modifications flatten torque ripple to under 1.5%, delivering silky-smooth manual back-drivability and enhanced force control safety compliance without relying on external torque sensors.

3. Supply Chain Security through Dual-Region OEM/ODM Manufacturing

Geopolitical friction, shipping bottlenecks, and tariff fluctuations have highlighted the fragility of single-region motion control sourcing. Modern procurement directors now mandate vendor qualification frameworks that include global engineering hubs paired with dual-location production infrastructure.

Telco’s strategic alignment—maintaining headquarter application design in Houston, TX, alongside audited manufacturing locations across North America and Asia—offers OEM buyers inventory buffers, localized assembly testing, and rapid prototype turnarounds without sacrificing high-volume cost advantages.
Technology Roadmap

Emerging Technological Trends in Robotic Actuator Design

The convergence of artificial intelligence, high-bandwidth fieldbus communications, and advanced materials science is redefining performance benchmarks for electric motor actuators.

Silicon Carbide (SiC) & GaN Drive Integration

Next-generation servo drivers are replacing legacy MOSFETs with Wide-Bandgap (WBG) semiconductors like Gallium Nitride (GaN) and Silicon Carbide (SiC). Operating at switching frequencies beyond 100 kHz, these switches eliminate audible noise, drastically reduce heat losses, and allow servo drives to shrink small enough to mount directly within the motor housing.

Dual Absolute Encoders & Safety Architectures

Modern joint actuators are incorporating dual-encoder topology: one high-resolution magnetic encoder on the motor shaft for speed control, and a second absolute optical encoder post-gearbox output to measure real-time position. This architecture compensates for gear deflection, backlash, and mechanical hysteresis while satisfying ISO 13849-1 Functional Safety requirements.

Advanced Thermal Potting & Phase-Change Materials

To maximize continuous torque output without exceeding thermal limits (Class F/H insulation), custom actuator builders are utilizing thermally conductive epoxy potting compounds. Epoxy resin fills internal air pockets around stator windings, conducting heat directly outward to aluminum/titanium heat-sink housings to boost continuous current capacity by 30% or more.

Technical Decision Matrix

Comparative Architecture Guide for OEM Actuator Selection

Match your mechanical load profiles, positioning requirements, and operational environments with the optimal actuator technology stack.

Actuator Architecture Primary Gear Technology Positional Accuracy Torque-to-Weight Ratio Ideal Robotic Application
Micro Digital Servos (SG90/MG90S/GX) Spur / Planetary Metal Gears ± 0.5° - 1.0° Moderate (10-35 kg.cm) Lightweight end-effectors, micro-grippers, UAV gimbals
Frameless Modular BLDC Actuators Strain Wave (Harmonic Drive) < 1.0 arcmin (Zero-Backlash) Ultra-High (Up to 120 N.m/kg) Collaborative arms, surgical robots, exoskeleton joints
High-Torque AC Servo Systems (XP/Lichuan) Direct / Precision Planetary ± 0.01° (20-Bit Encoder) High Continuous (0.75kW - 1.3kW) Industrial gantries, CNC automation, heavy AGV traction
Closed-Loop Smart Actuators Integrated Multi-Stage Planetary ± 0.1° (Magnetic Encoder) High Peak Torque (15-35 kg.cm) Quadruped robotics, dynamic mobile platforms, indexing
Frequently Asked Questions

OEM/ODM Robotic Actuator Procurement & Engineering FAQ

Addressing the technical, operational, and commercial questions raised by system integrators and sourcing teams during custom motor design programs.

What is the typical Minimum Order Quantity (MOQ) for custom motor programs?

Custom OEM programs typically begin at 250 to 500 units annually for modified standard platforms (custom shafts, unique winding constants, special lead wires, or alternative gear ratios). Fully bespoke clean-sheet electromagnetic designs—requiring new lamination stamping dies or custom housing castings—are typically scoped from 1,000 units per year. Prototype and pilot lot batches (5 to 25 units) are fully supported during initial engineering design reviews (EDR) to validate performance before committing to mass production tooling.

How long does the custom actuator development process take from specification to prototype delivery?

For modified standard platforms, prototype samples are generally delivered within 4 to 6 weeks. For clean-sheet custom OEM developments involving Finite Element Analysis (FEA) electromagnetic modeling, dedicated gearbox housing tooling, and custom PCB drive design, production-grade prototypes require 10 to 14 weeks. Design for Manufacturability (DFM) reviews occur concurrently to streamline transition to mass production.

Which technical parameter sheet should an OEM supply when requesting a quote?

To rapidly evaluate your application, our engineering team requires: (1) Continuous and peak torque requirements (N.m or kg.cm), (2) Target output speed (RPM) and acceleration profiles, (3) Supply voltage range (VDC or VAC), (4) Mechanical envelope limits and weight budgets, (5) Expected operational duty cycle, ambient temperature range, and Ingress Protection (IP) rating, and (6) Preferred feedback protocols (e.g., Incremental, Absolute SSI/BiSS-C, CANopen, EtherCAT).

How do you mitigate cogging torque and acoustic noise in quiet medical robotic applications?

We suppress cogging torque through advanced stator lamination skewing, optimized slot-pole ratio selection, and precision air-gap geometry modeling. In addition, we utilize high-fill slot copper winding, precision-ground gear teeth (AGMA Class 10+), and cleanroom-compatible synthetic lubricants to lower acoustic emission levels below 45 dBA for quiet laboratory and medical environments.

Can your engineering team supply fully integrated actuator assemblies with match-paired drives and battery packs?

Yes. As part of the Telco Group structure (combining TelcoMotion, Medical & Laboratory, and Custom Energy Storage divisions), we engineer complete motion and power systems. We deliver pre-validated subassemblies combining BLDC motors, strain wave gearheads, absolute dual encoders, smart FOC drivers, and custom sodium-ion or lithium battery packs under a single OEM part number.

What quality control measures guarantee lot-to-lot repeatability across multi-year production runs?

All production lines operate under strict ISO 9001 and ISO 13485 quality systems. Every individual actuator unit undergoes automated End-of-Line (EOL) testing evaluating insulation resistance, high-pot voltage safety, no-load current draw, back-EMF symmetry, torque ripple, thermal rise, and encoder signal integrity. Comprehensive First Article Inspection (FAI) reports and PPAP Level 3 documentation are provided upon request.

Structured Execution Roadmap

Our 5-Stage OEM/ODM Custom Design Engineering Process

From back-of-the-envelope concept sketches to multi-thousand unit manufacturing releases, our Houston-led engineering framework eliminates design risk at every stage.

01

Requirements & Load Profiling

We analyze your mechanical load curves, environmental constraints, lifetime duty cycles, and target cost points to identify potential failure modes before prototyping starts.

02

FEA Simulation & Architecture Proposal

Our engineers perform electromagnetic Finite Element Analysis (FEA) and gear stress simulations, submitting 2D/3D CAD models, efficiency curves, and fixed commercial proposals.

03

Rapid Prototyping & Bench Testing

Functional prototypes are assembled and subjected to accelerated life testing (ALT), thermal rise evaluation, shock/vibration stress, and acoustic chamber validation.

04

DFM Tooling & PPAP Approval

Production tooling, lamination dies, and assembly jigs are finalized under strict revision control. Sample lots undergo full PPAP inspection sign-off.

05

Volume Production & Buffer Stocking

Commercial production launches with automated EOL testing. Local warehouse buffer stocking in Houston, TX guarantees uninterrupted supply chain flow.

Partner with an Established Robotic Actuator Manufacturer

Whether you require customized winding configurations for a medical surgical robot or continuous high-volume AC servo supplies for industrial automation, Telco’s application engineering team is ready to review your specifications.